 1 / 401
Bot 4
OutdoorAutonomous4×4Perception
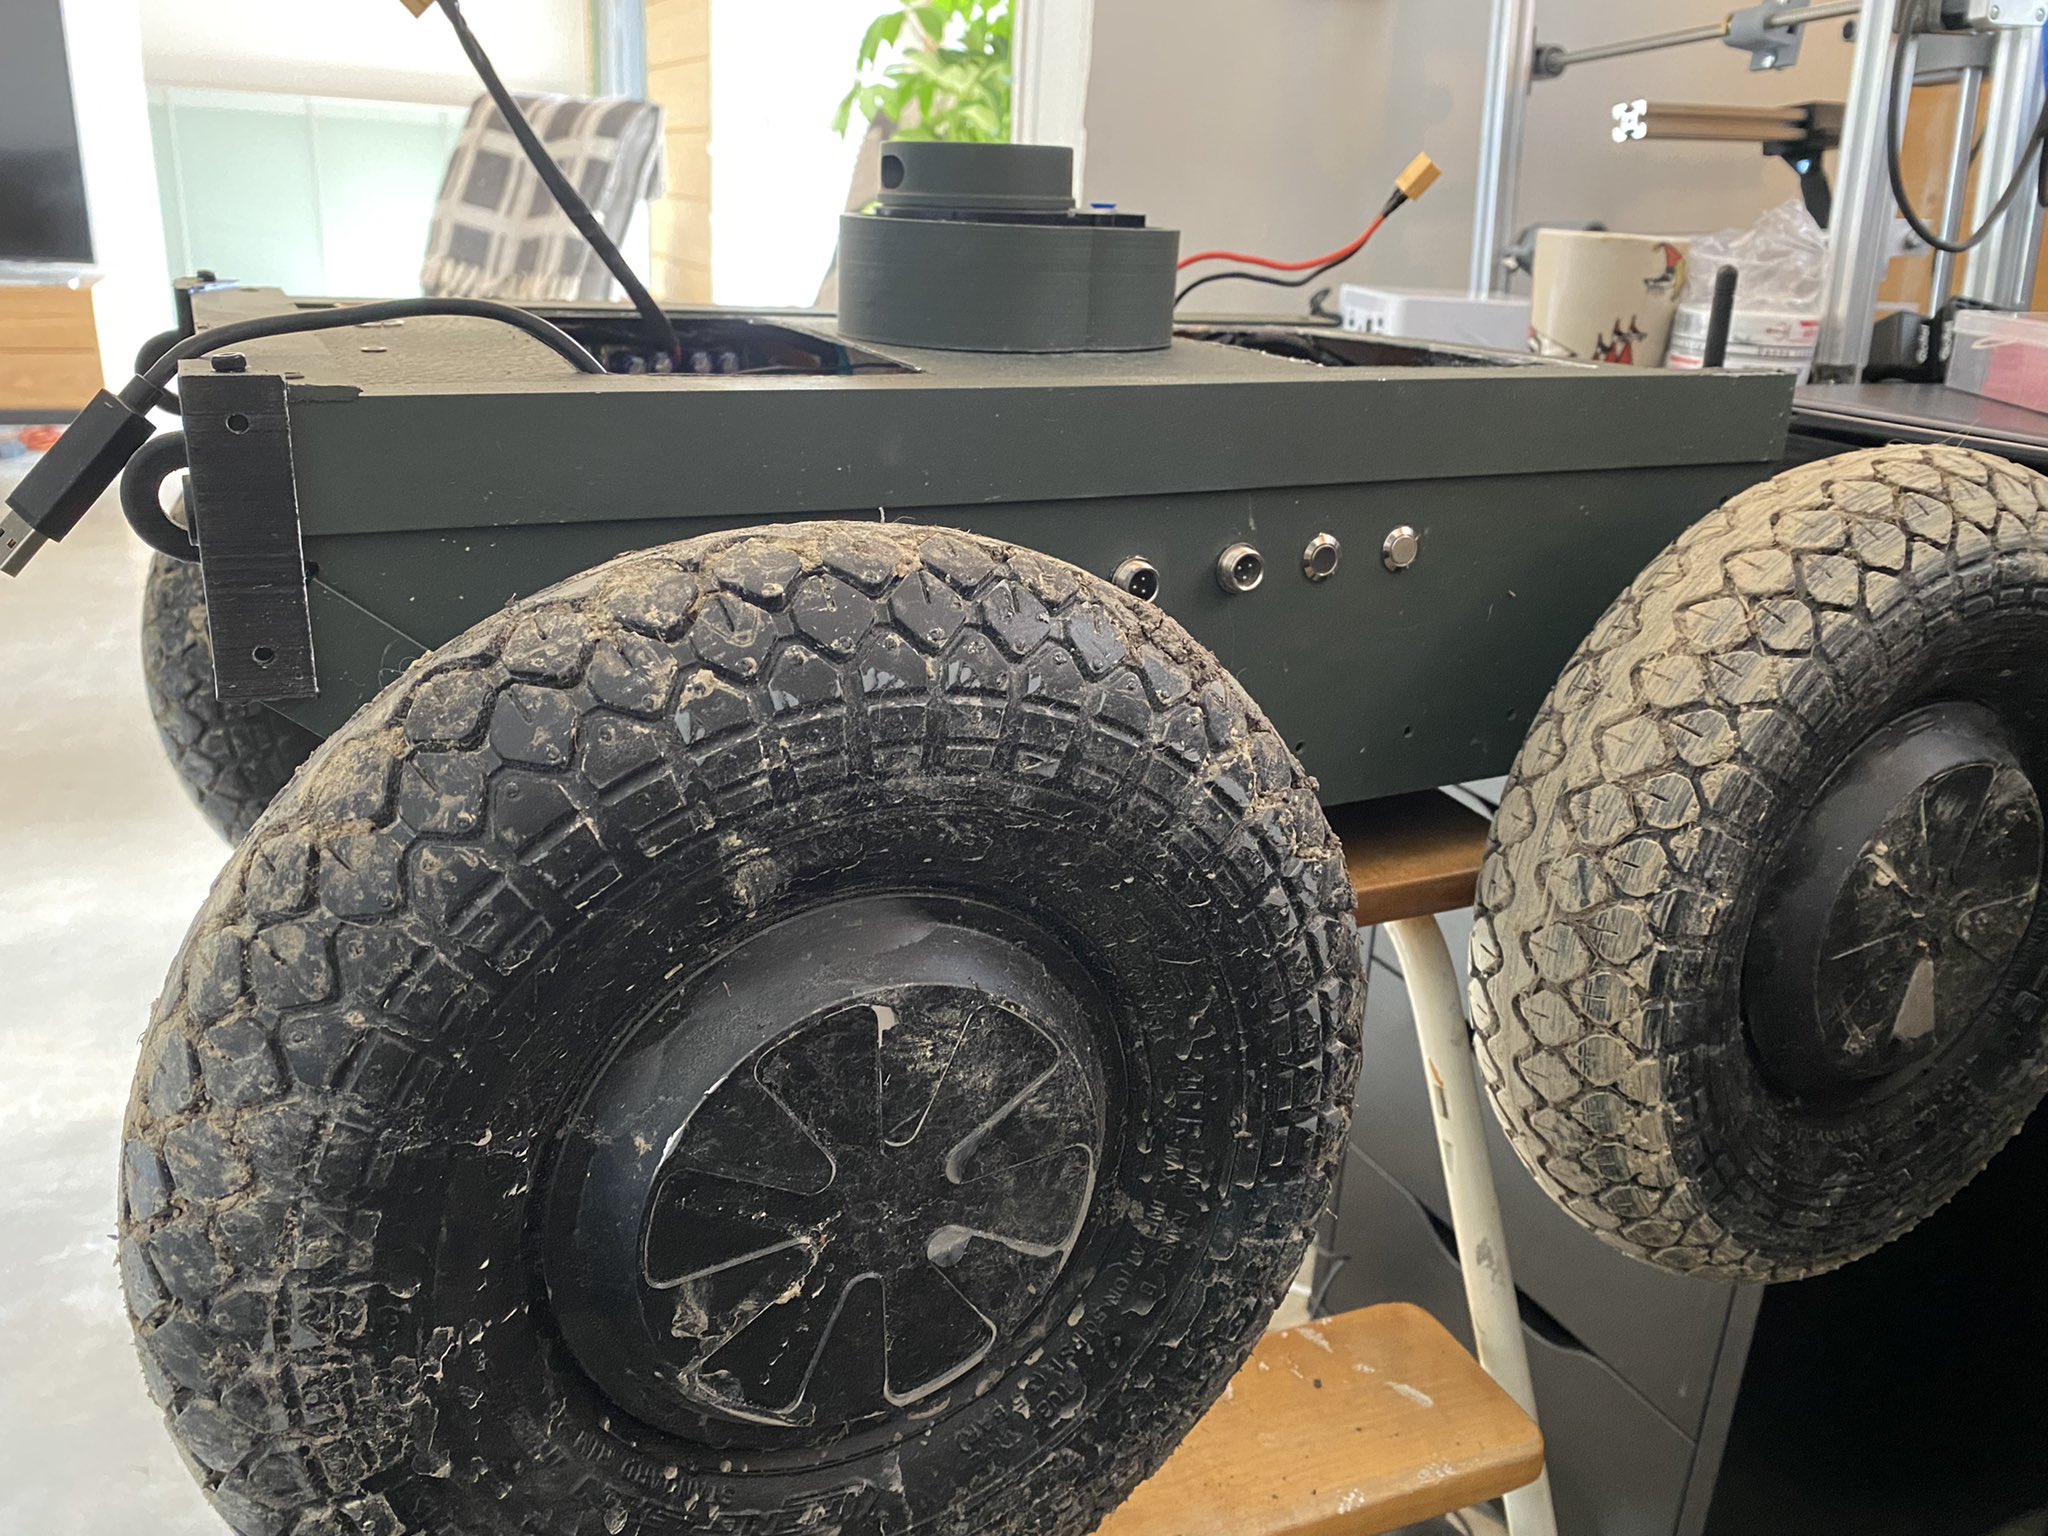
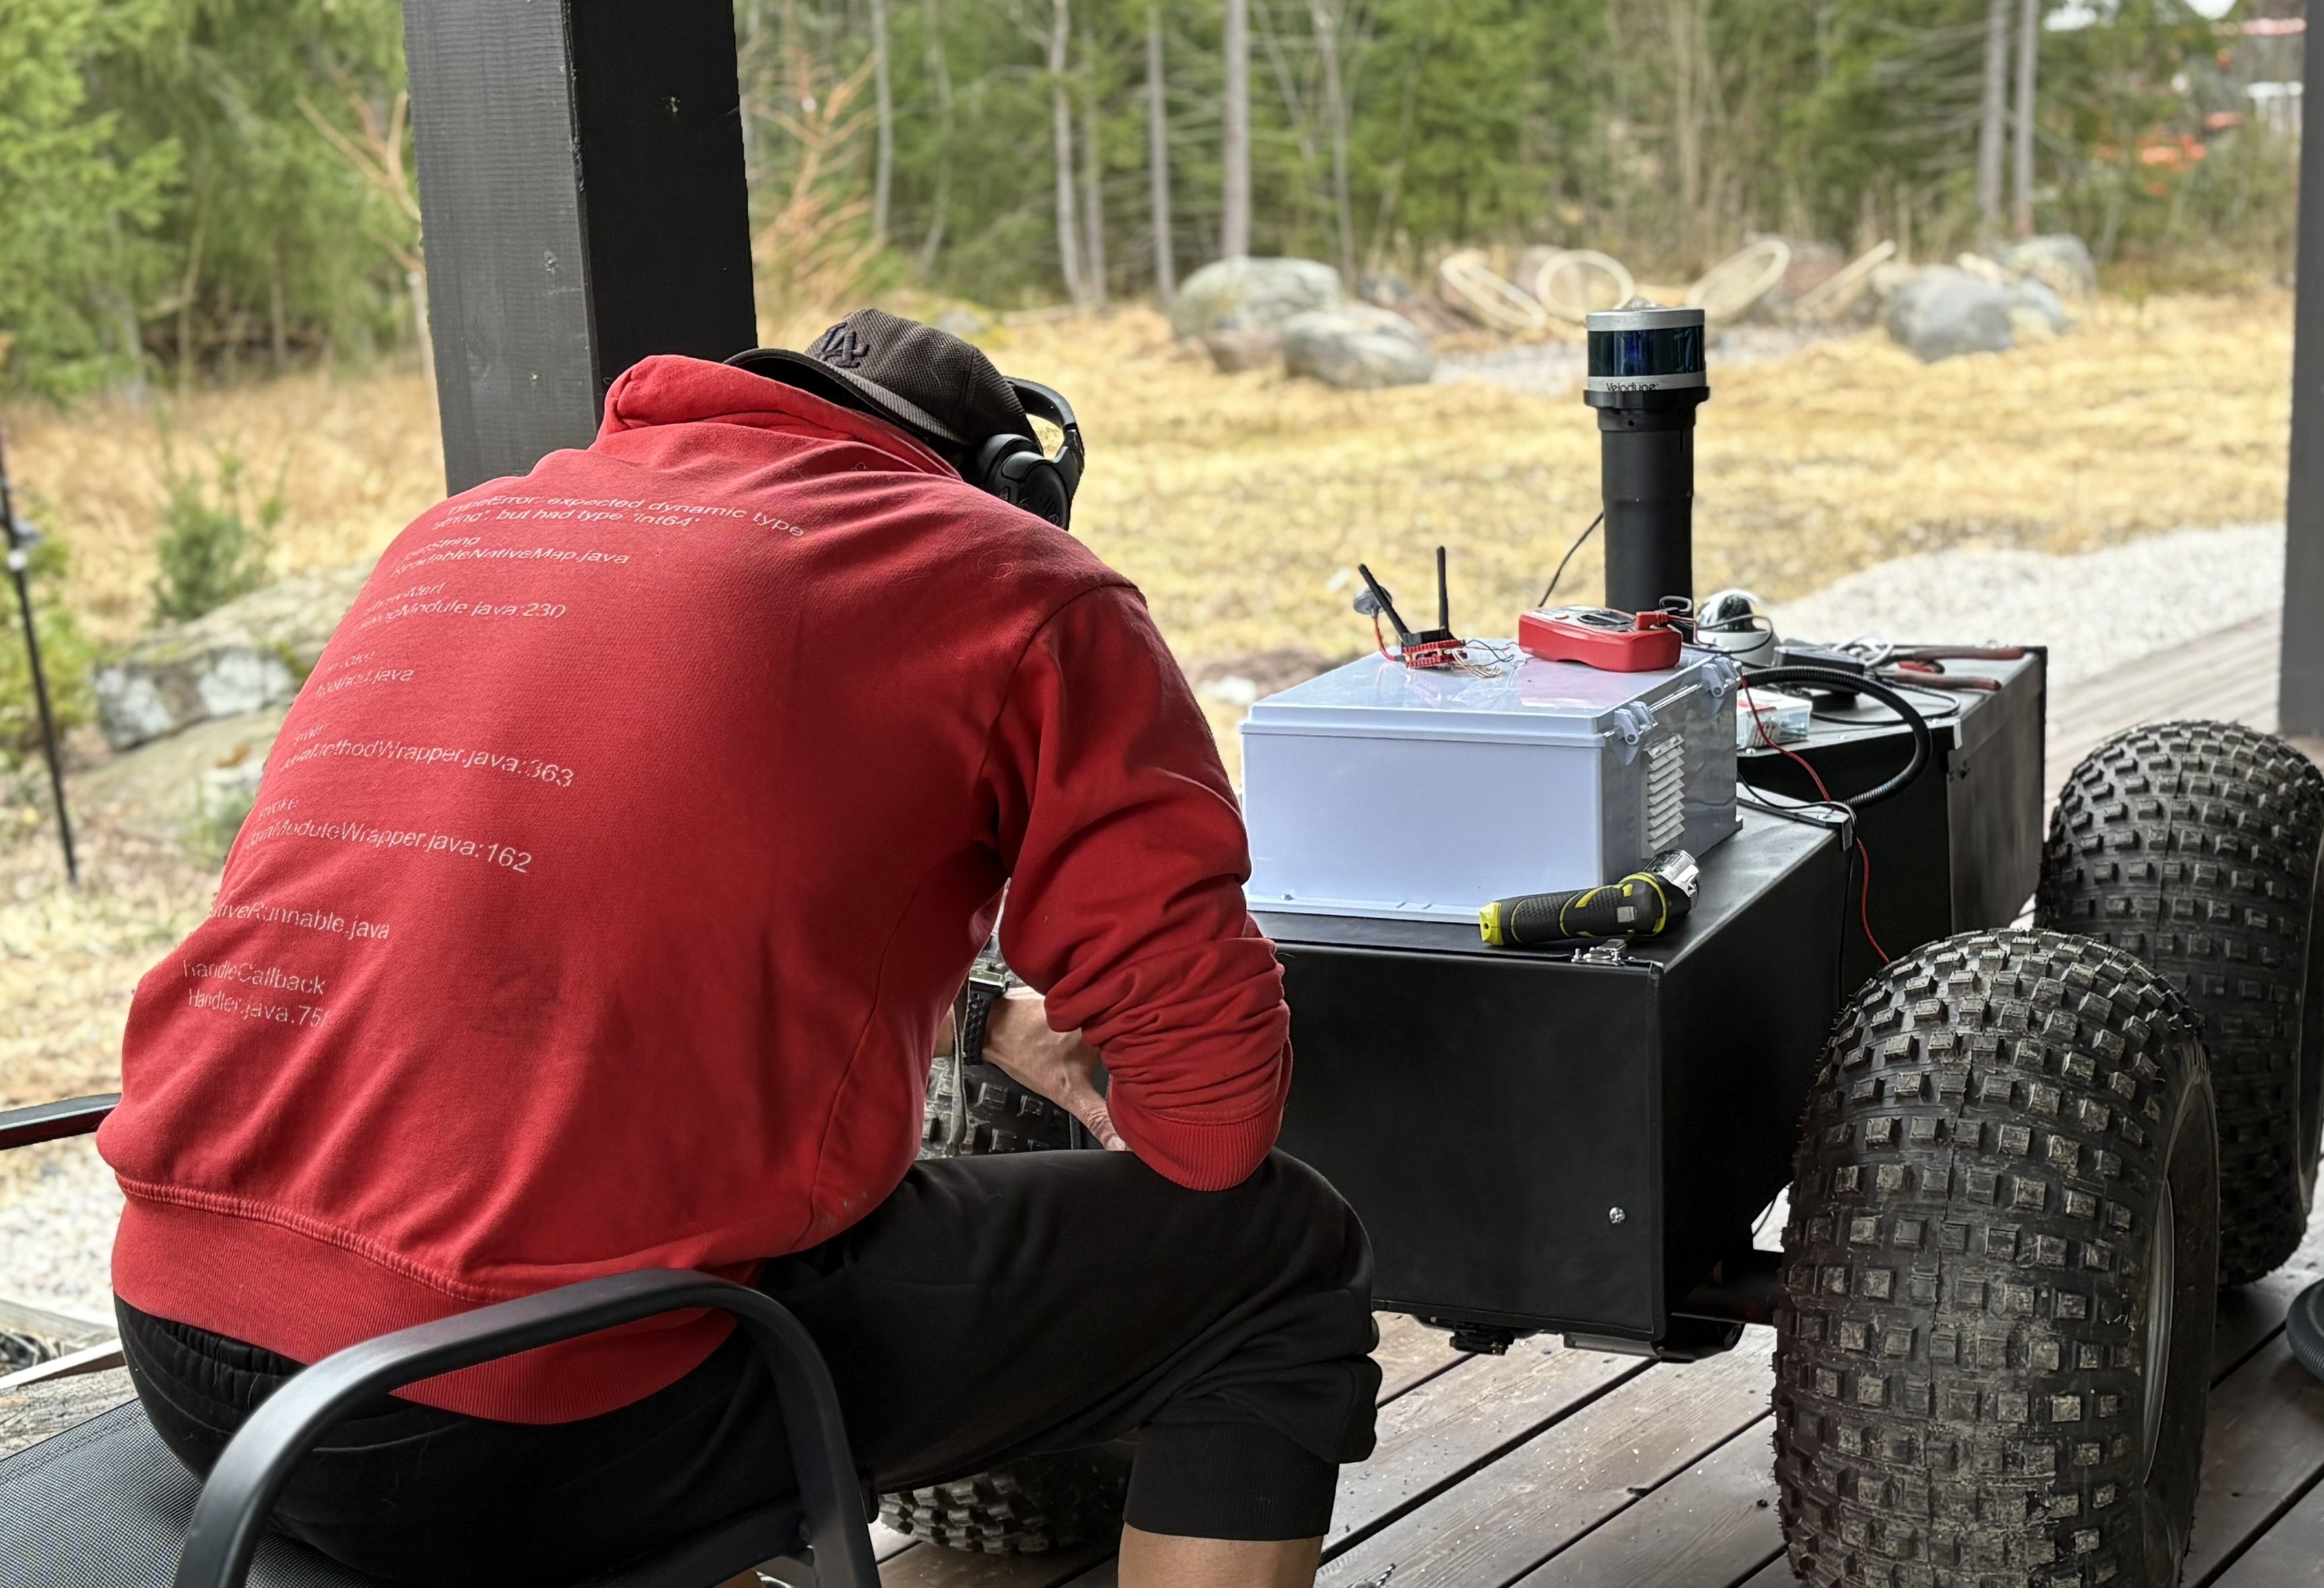
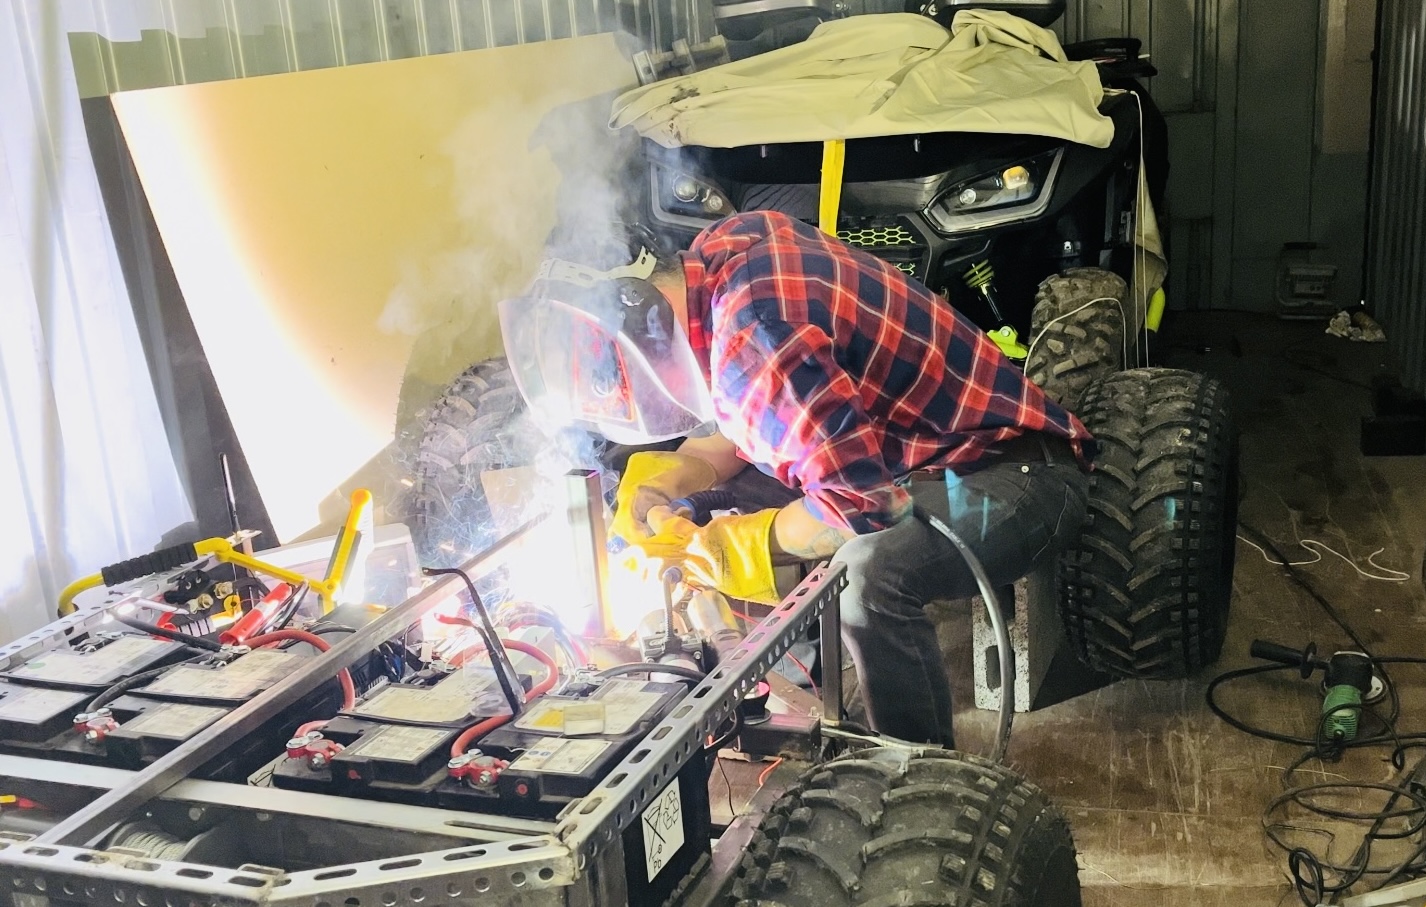
Compact 4×4 autonomous outdoor platform with onboard perception. Early full-stack mobile robot covering mechanical design, sensor integration, and autonomy software.
Somewhere in the Helsinki Area
Designing and deploying complete hardware-to-code platforms, custom CAD, motor controllers, and autonomy.
 FIELD WORK
Dossier
8 systems on record
1 / 401Compact 4×4 autonomous outdoor platform with onboard perception. Early full-stack mobile robot covering mechanical design, sensor integration, and autonomy software.
 1 / 402
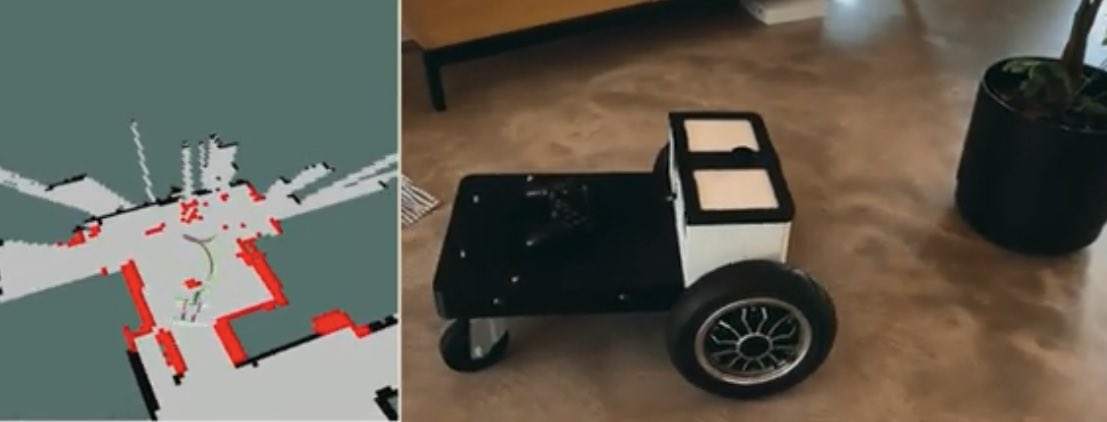
Fully autonomous indoor differential-drive robot developed for logistics applications. Complete stack from custom chassis and drive system through localization, mapping, and navigation.
 1 / 203
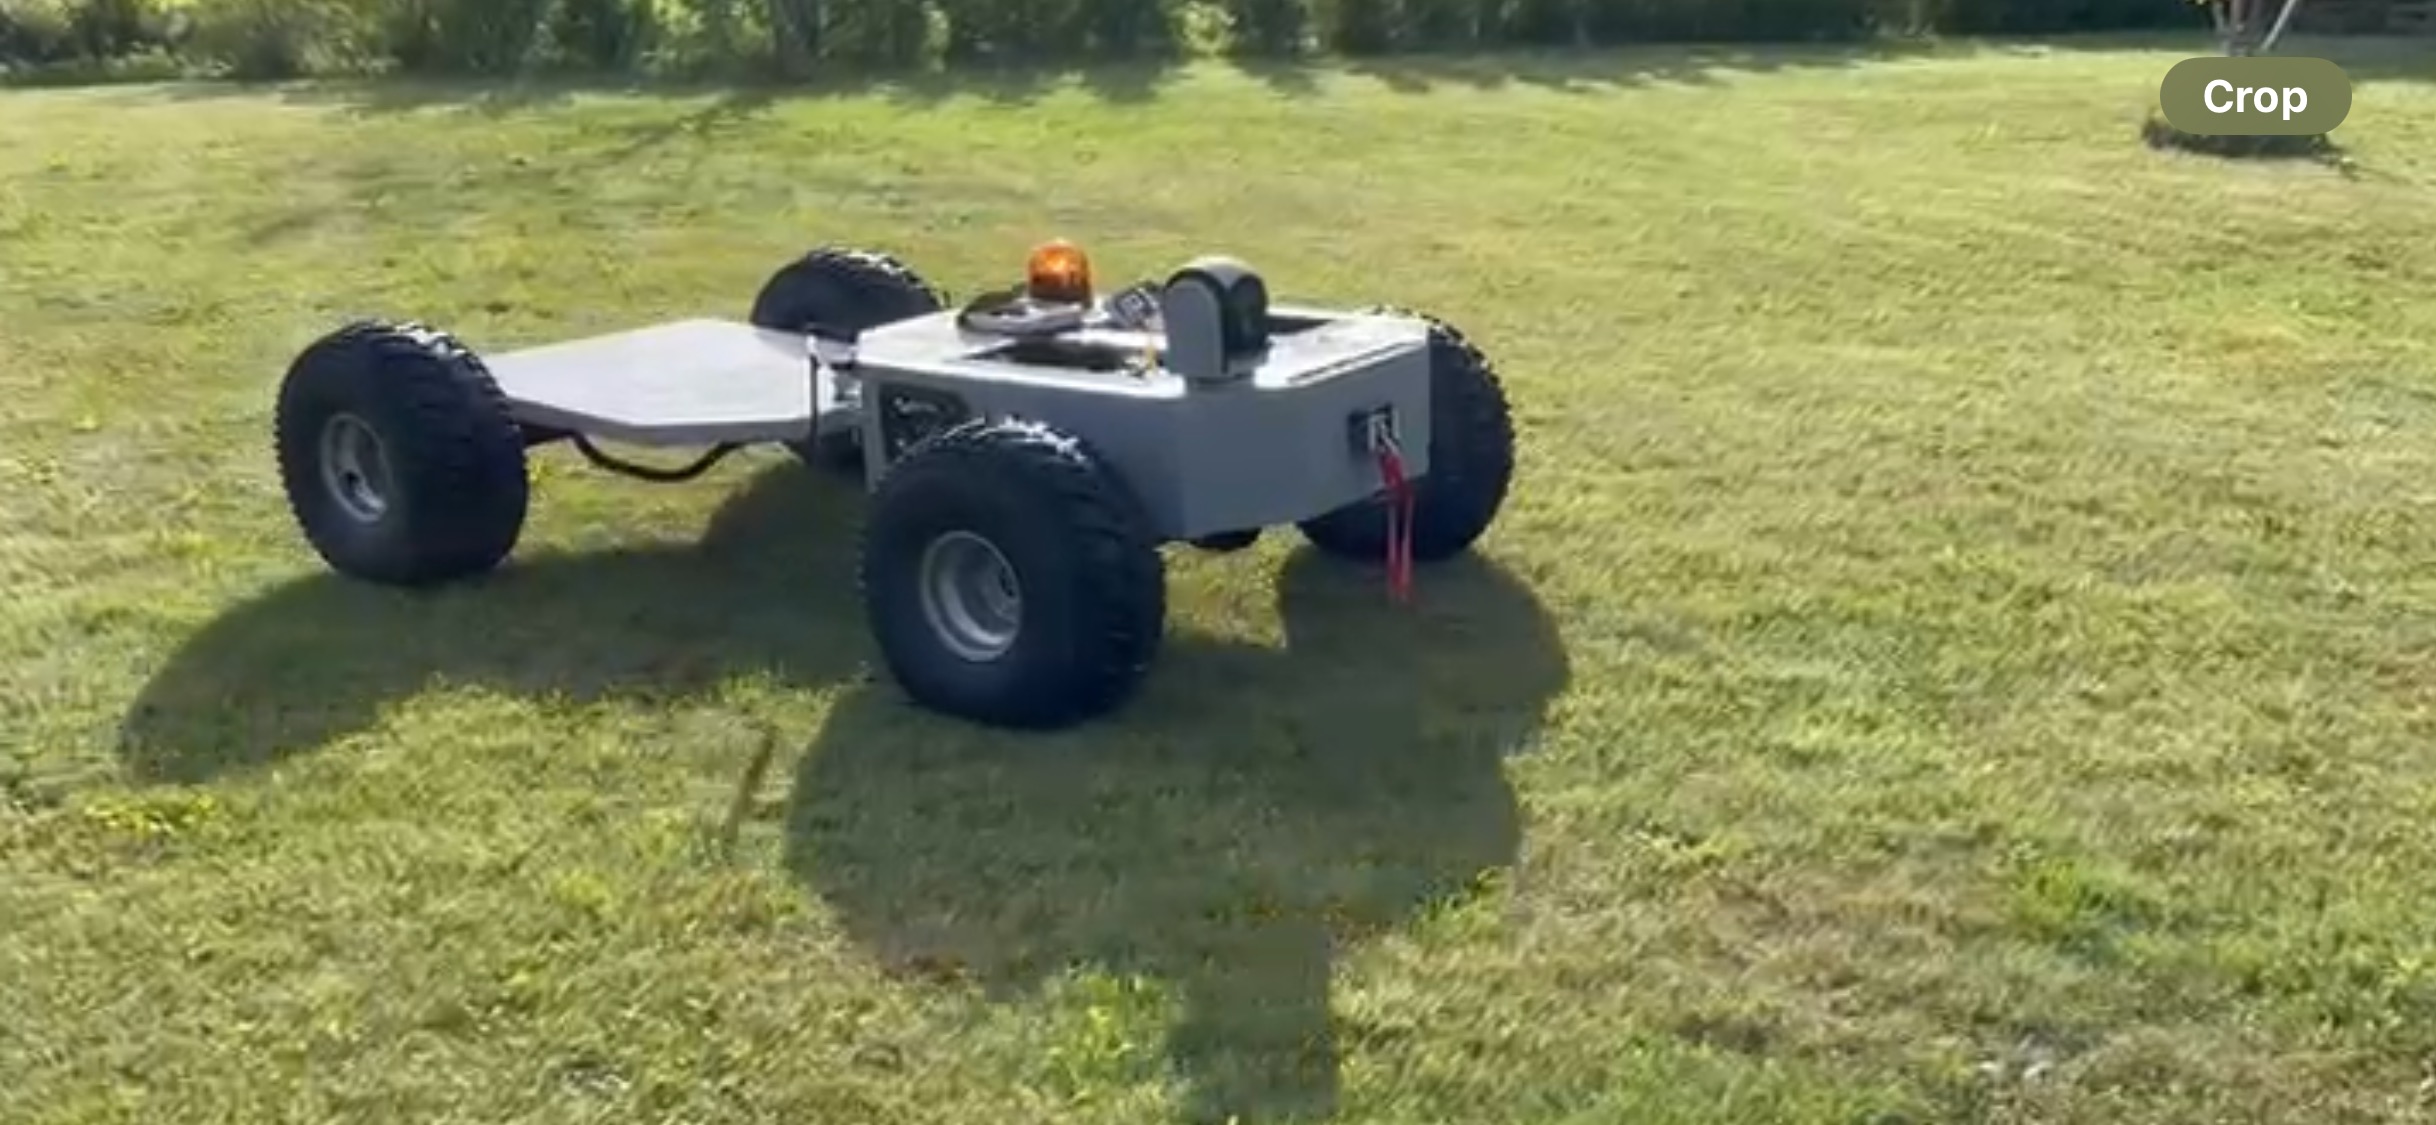
Heavy-duty articulated-steered outdoor UGV built for harsh environments. Features high payload and tow capacity, modular attachments including snow plow and defense modules, plus full mechanical, electrical, and autonomy integration.
 1 / 404
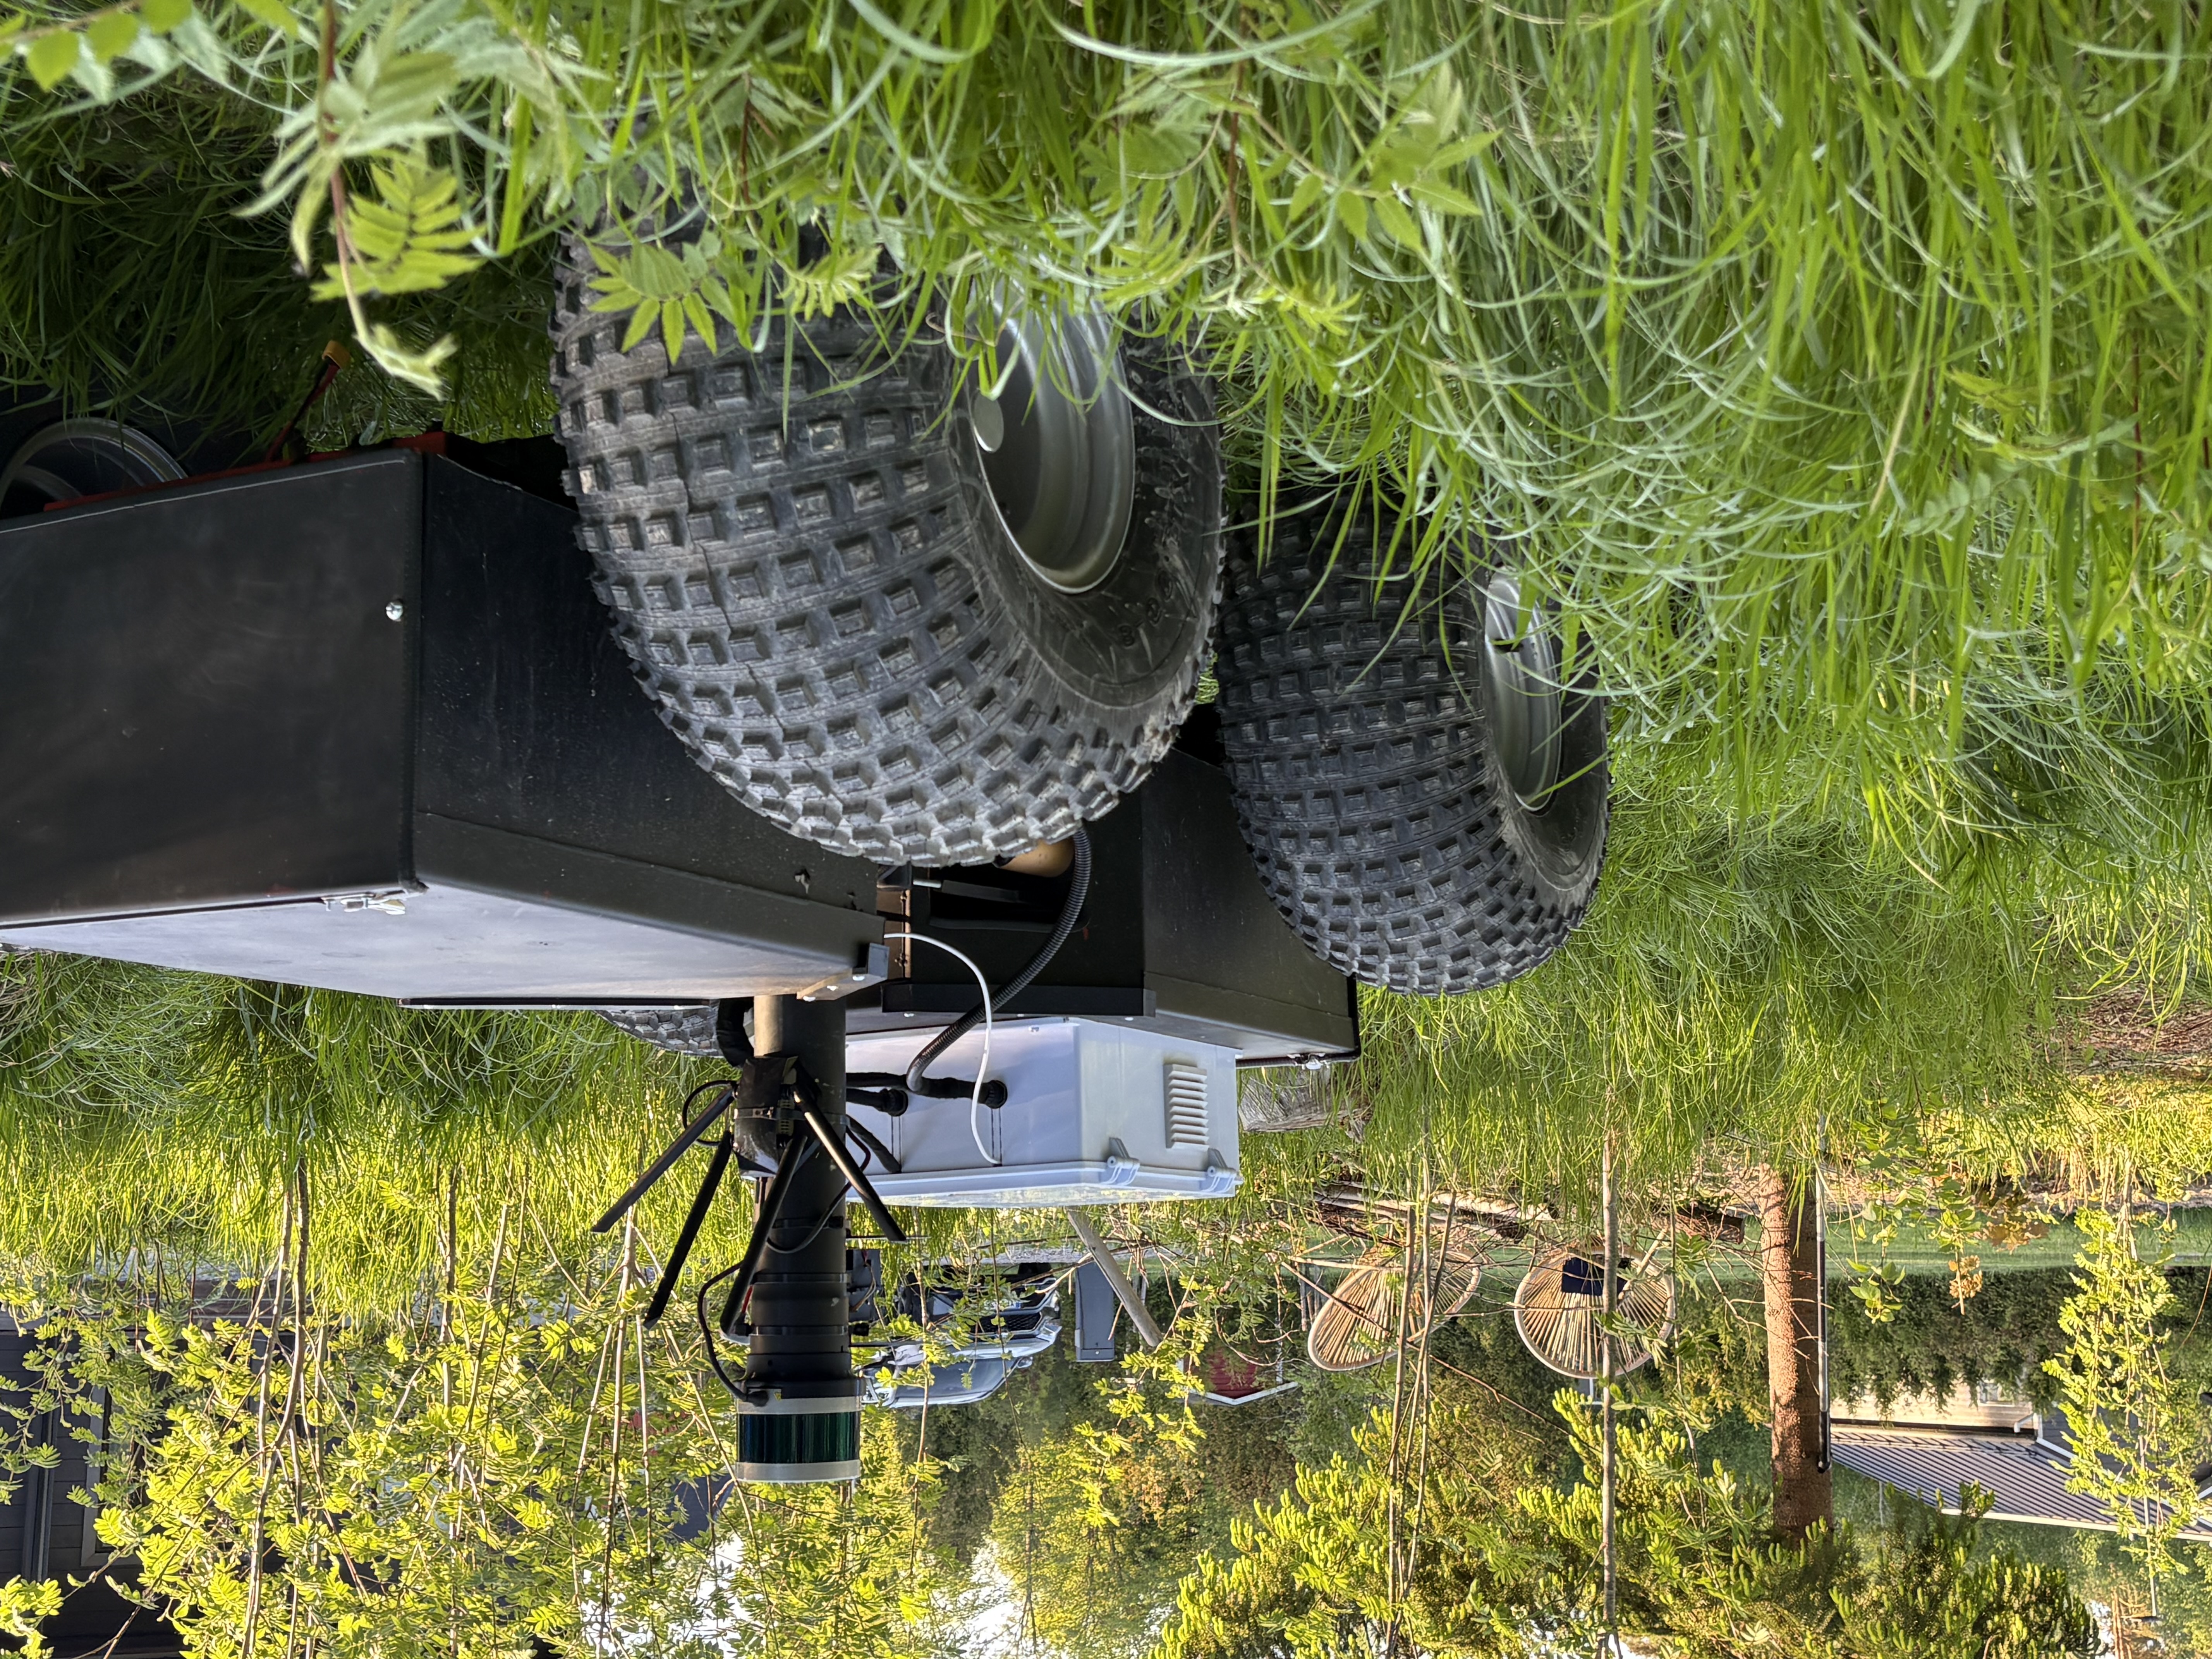
Compact outdoor research UGV with articulated steering and a purpose-built climate-controlled electronics enclosure. Designed for reliable operation in demanding field conditions with full sensor and autonomy suite.
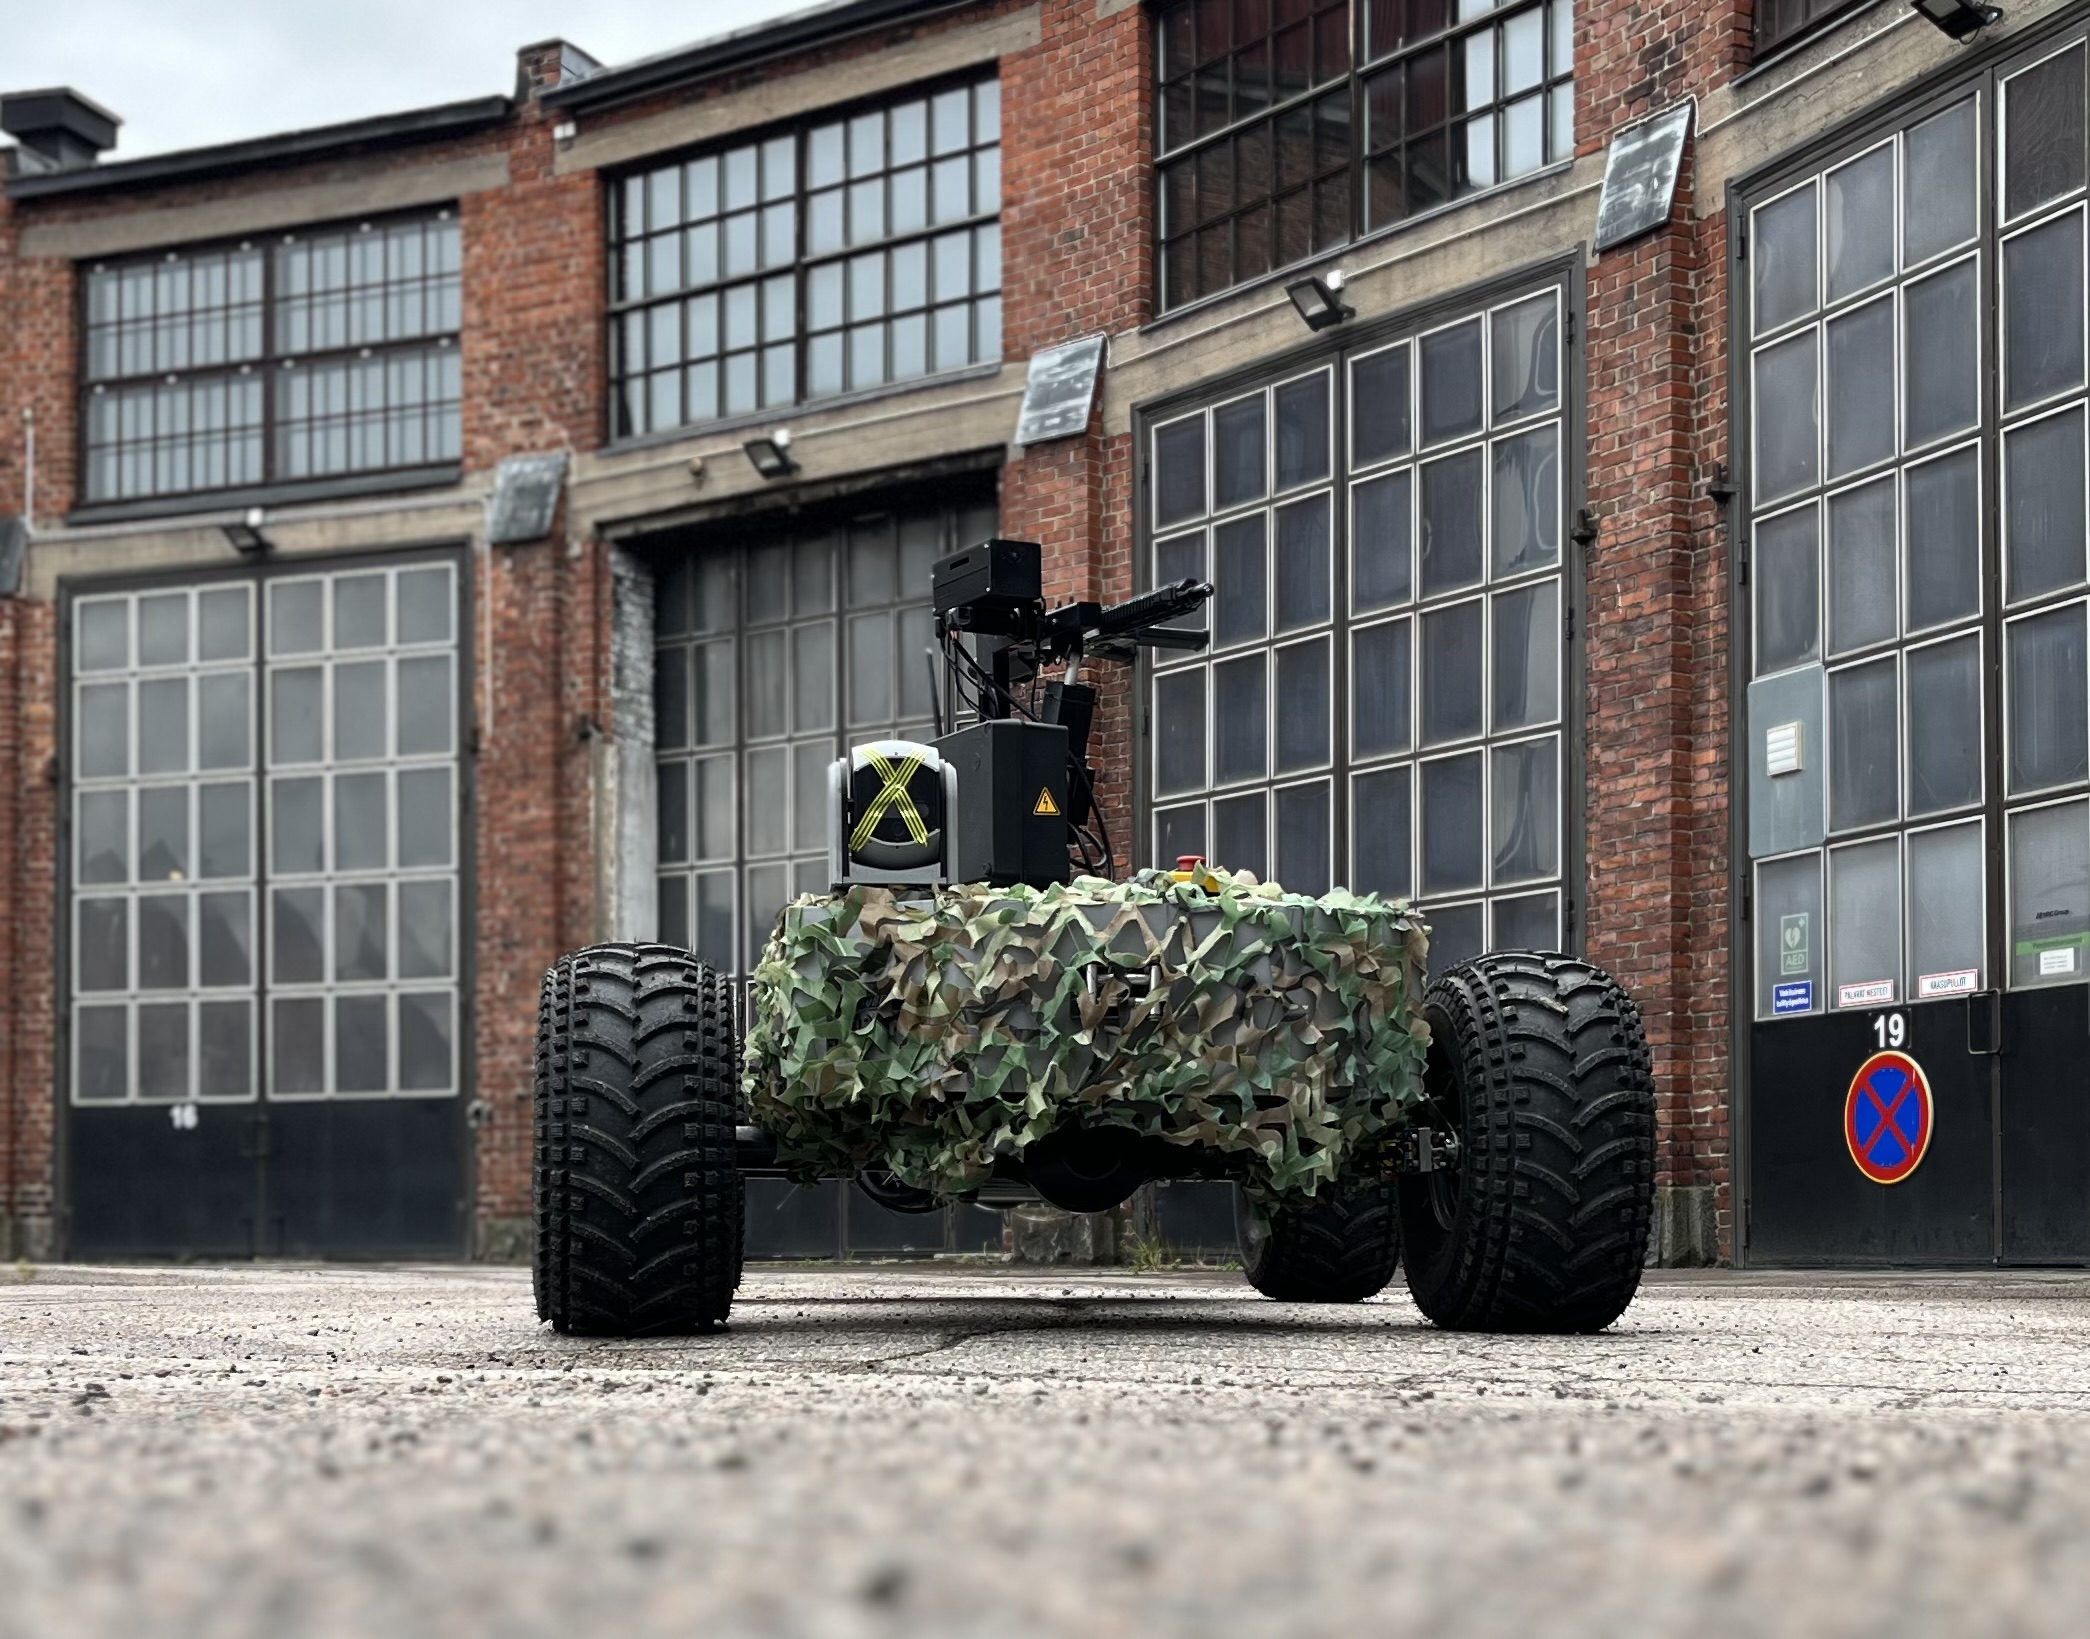 1 / 205
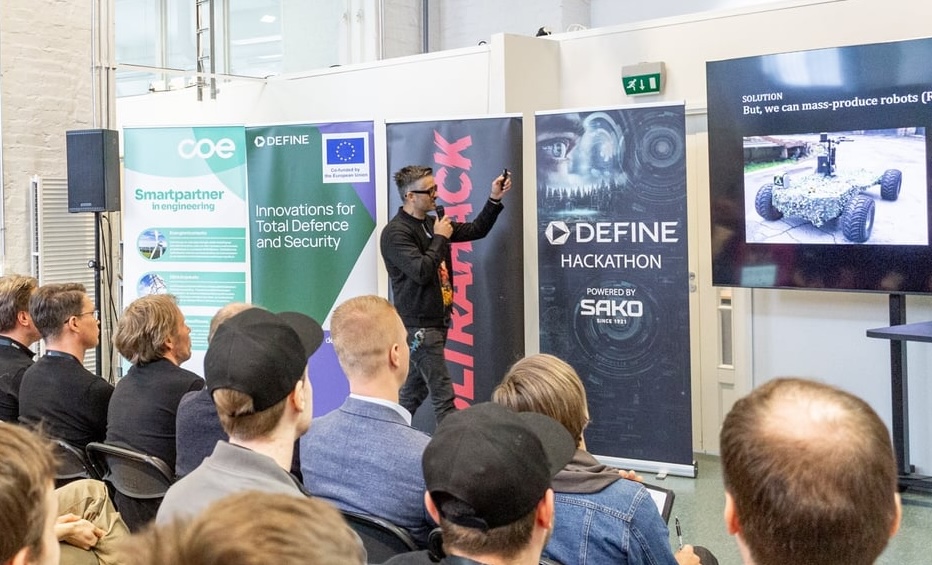
Autonomous targeting turret with weapon mount, designed and integrated onto a UGV platform during a 48-hour defense hackathon. Full end-to-end development of mechanics, sensing, and control. Achieved 2nd place with team of 3.
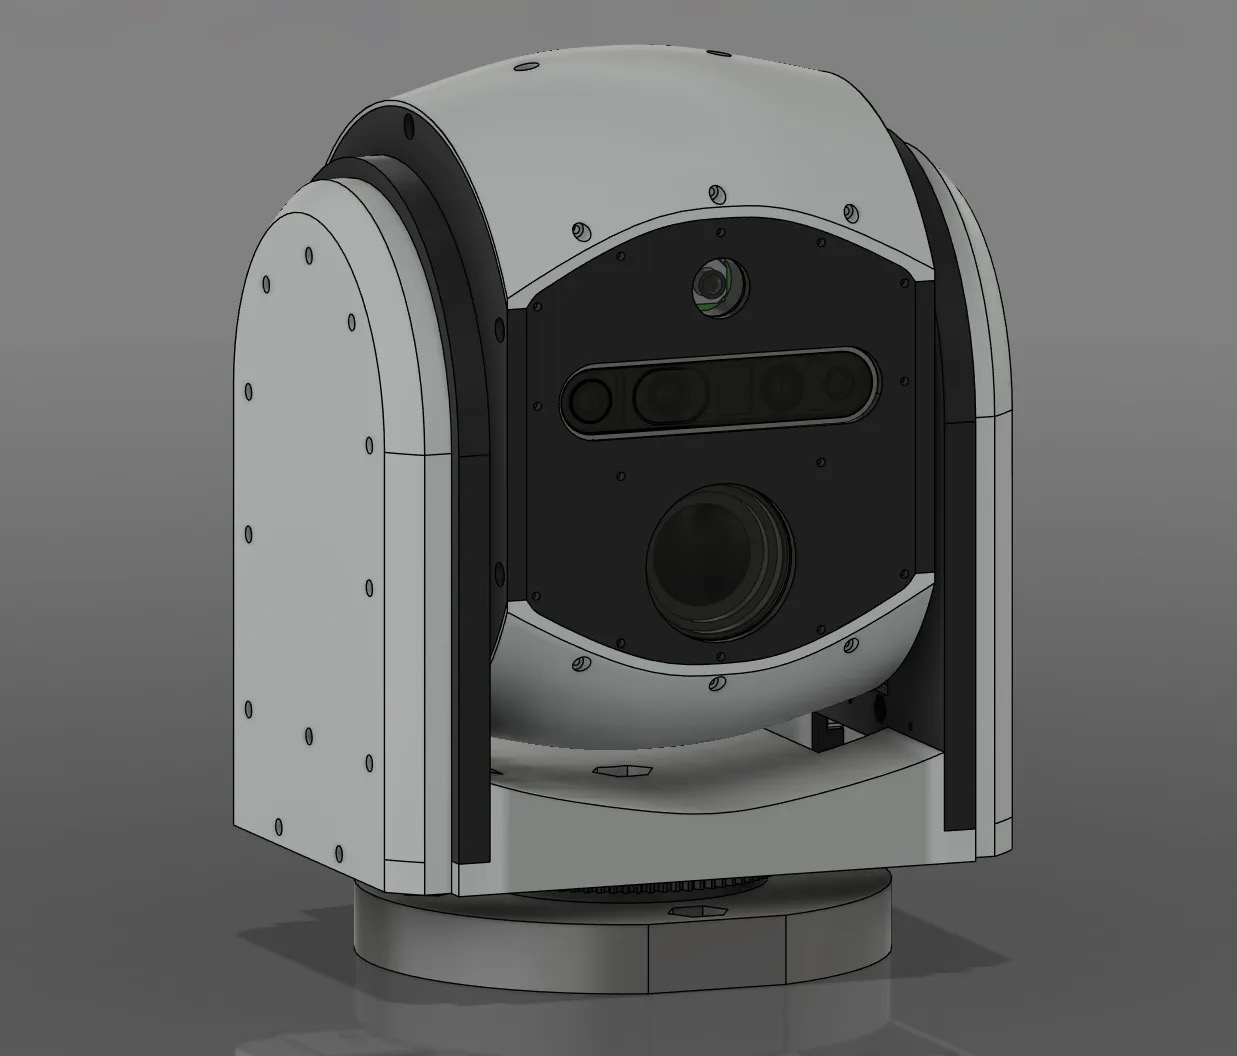 1 / 506
Compact pan-tilt camera system designed for large mobile robots. Fully custom mechanical design with dual-axis actuation and embedded control, created as a practical low-cost alternative to commercial units.
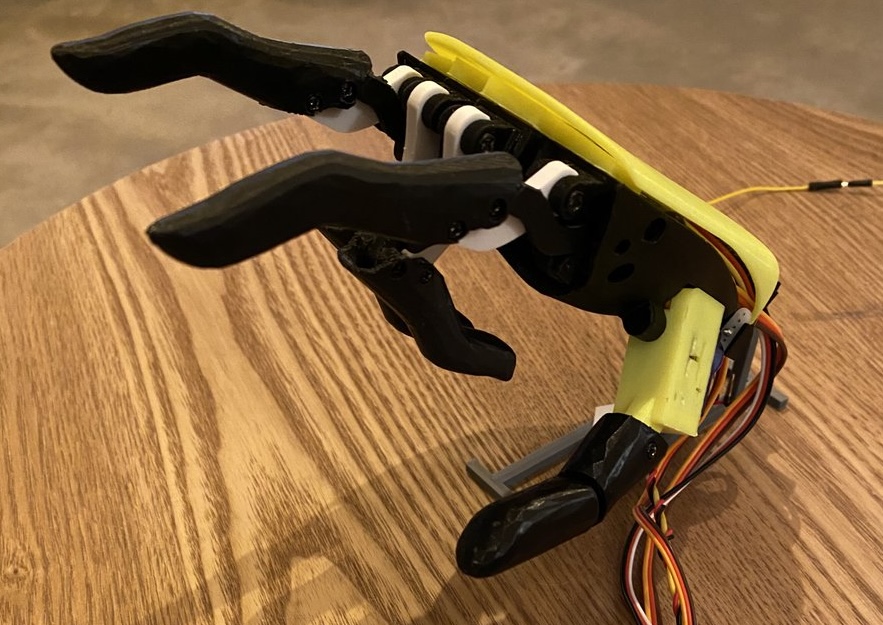 1 / 207
Myoelectric prosthetic hand controlled by muscle signals. Complete development cycle including mechanical design, custom electronics, embedded firmware, and real-time signal processing.
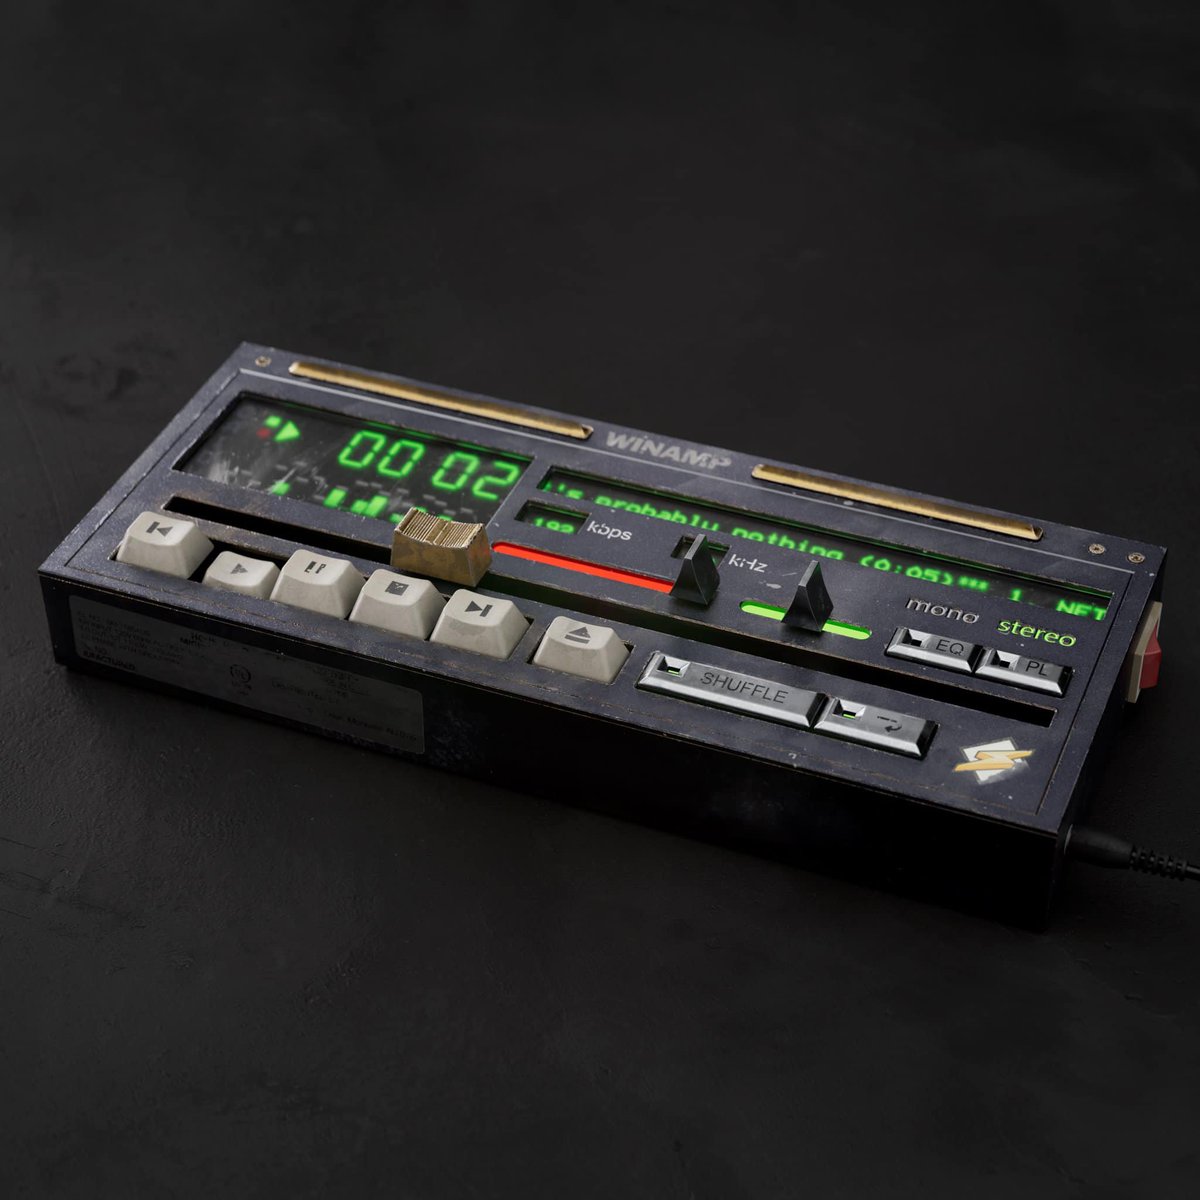 1 / 208
Hardware recreation of the classic media player with physical controls and custom enclosure. Full embedded architecture and user interface developed from the ground up. Currently being revived with a small team. (3D concept by Rick Gude)
Toolchain